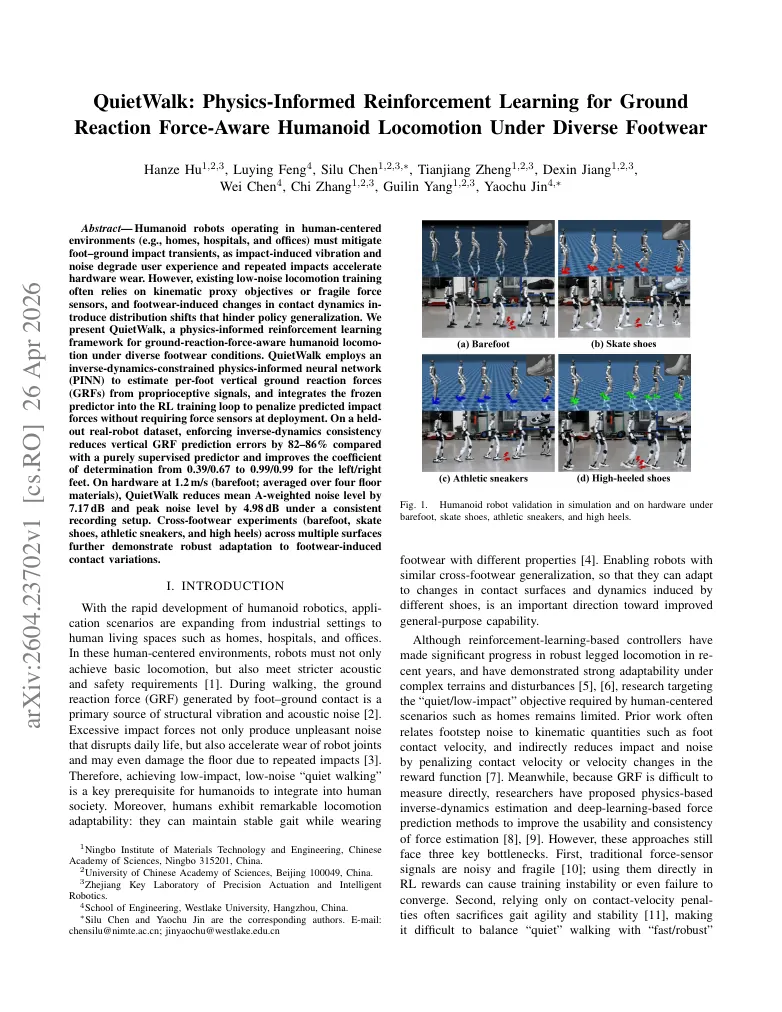
QuietWalk: Physics-Informed Reinforcement Learning for Ground Reaction Force-Aware Humanoid Locomotion Under Diverse Footwear
Teaches humanoids to walk more quietly across shoes and floors by predicting foot impact forces without force sensors.
Terrain, gait, robustness, and agile movement.


Teaches humanoids to walk more quietly across shoes and floors by predicting foot impact forces without force sensors.
Lets humanoids navigate clutter from language and camera views by outputting whole-body action chunks.
Keeps damaged or knocked-down humanoids moving by blending recovery, crawling, and walking behaviors.

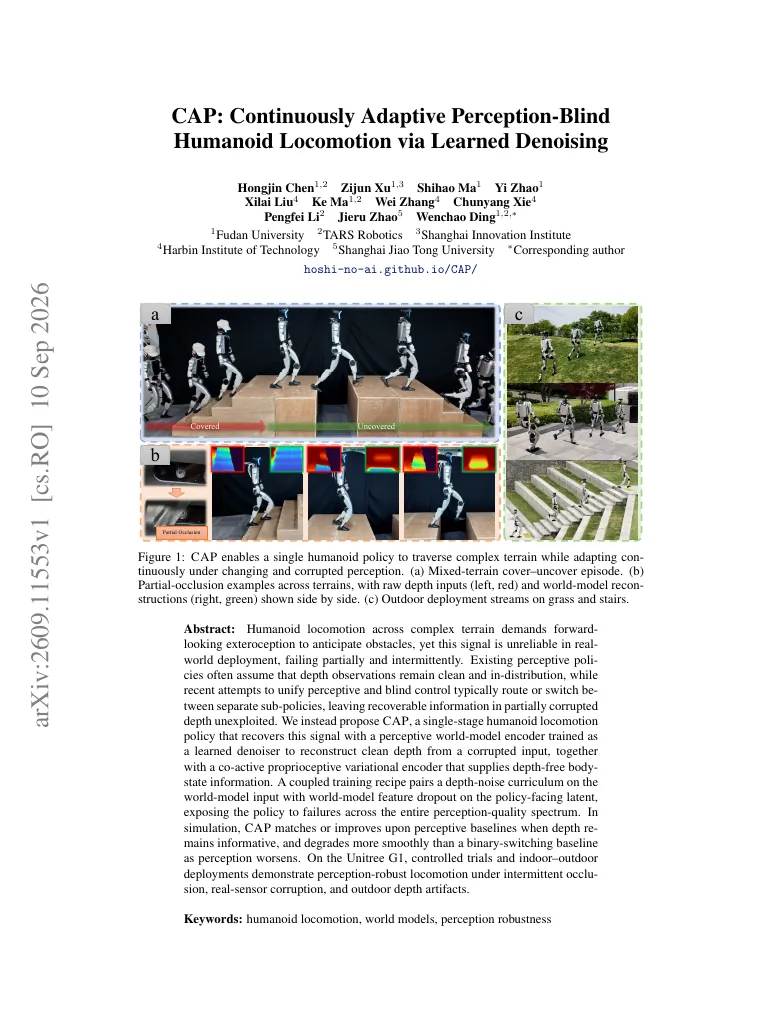
Lets humanoids keep walking when depth perception is missing or corrupted by denoising what the robot should see.

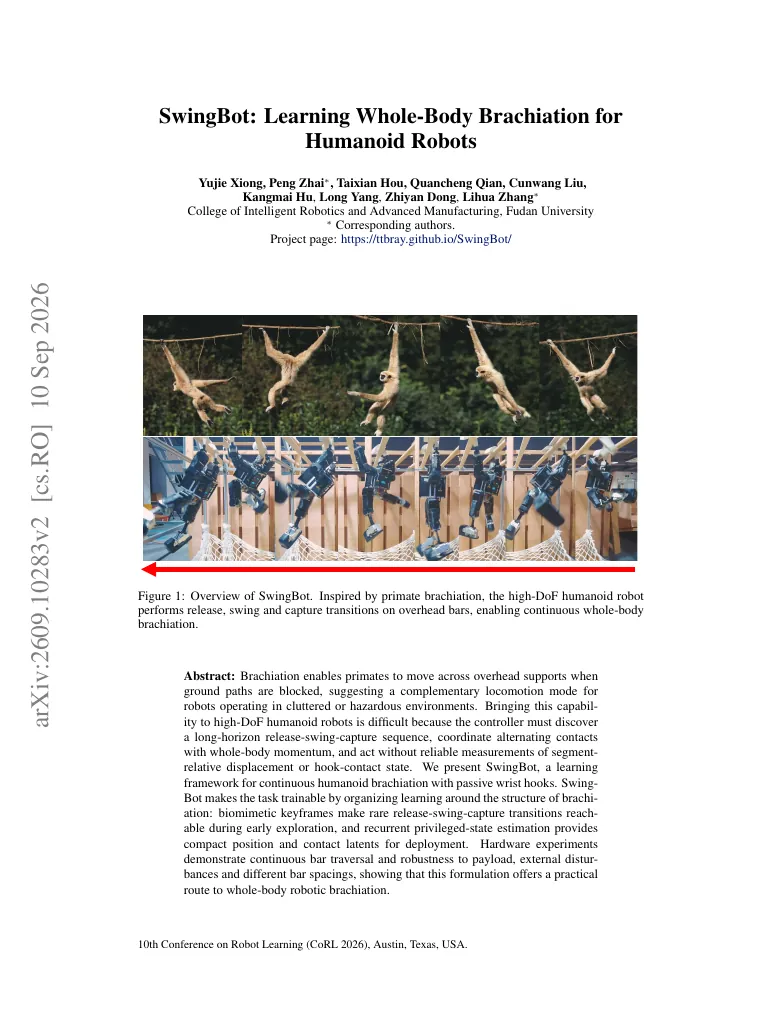
Teaches humanoids to swing across bars with hook hands and recover from missed contacts.
Teaches quadrupeds to dodge sudden moving obstacles and recover when avoidance fails.
Reference motion, imitation, retargeting, and behavior priors.

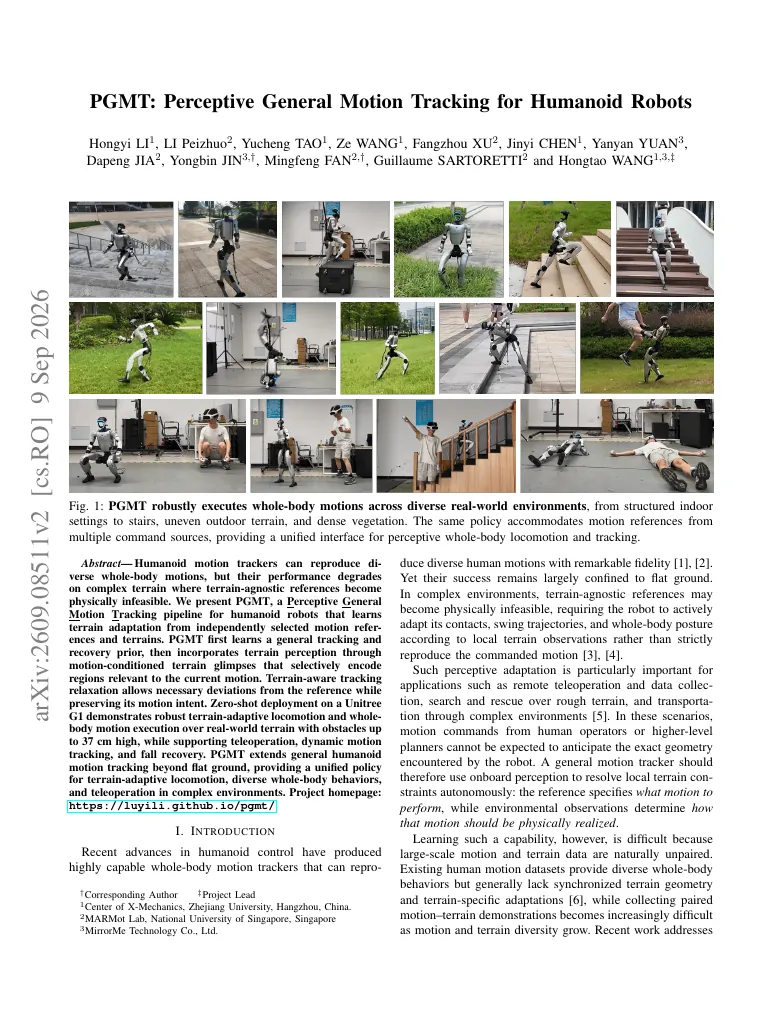
Tracks whole-body humanoid motions on uneven terrain by combining terrain perception with motion tracking.
Whole-body task contact: feet, torso, hands, and objects.

Teaches humanoid soccer robots to combine dribbling, trapping, shooting, and movement under one policy.
MPC, impedance, safety layers, and whole-body coordination.

Adds task-focused vision to a pretrained whole-body controller so humanoids adapt to terrain, interaction, and manipulation.
Benchmarks, datasets, rewards, simulators, and tooling.


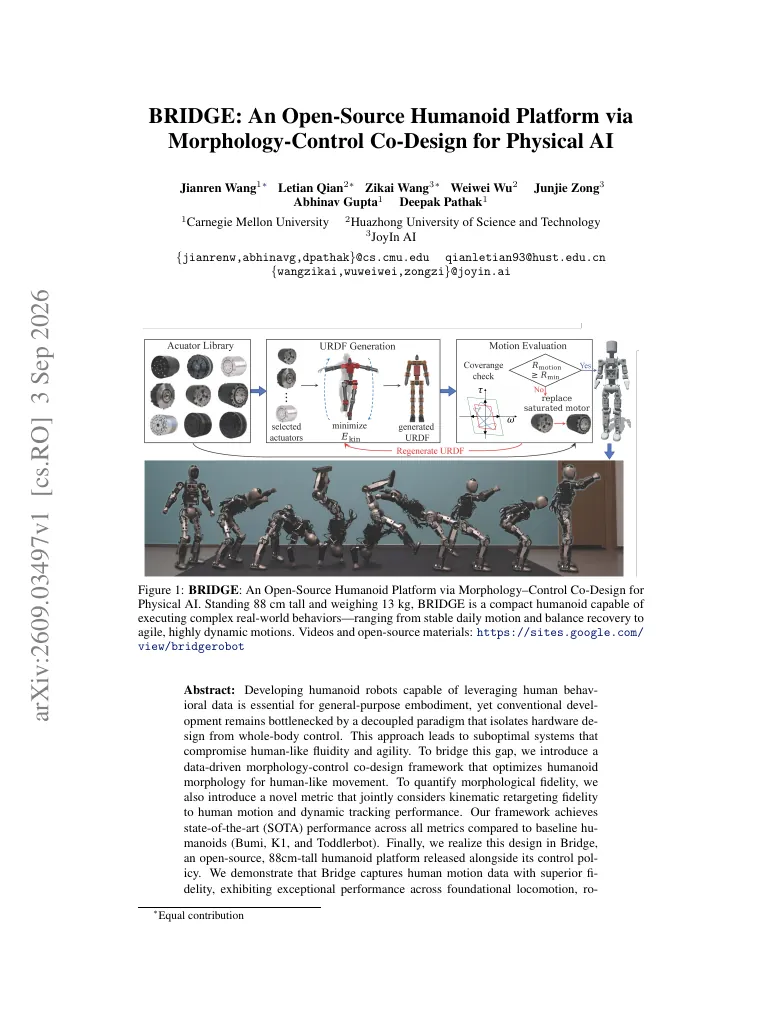
Builds an open low-cost humanoid and co-designs the body and controller so learned motions transfer to hardware.

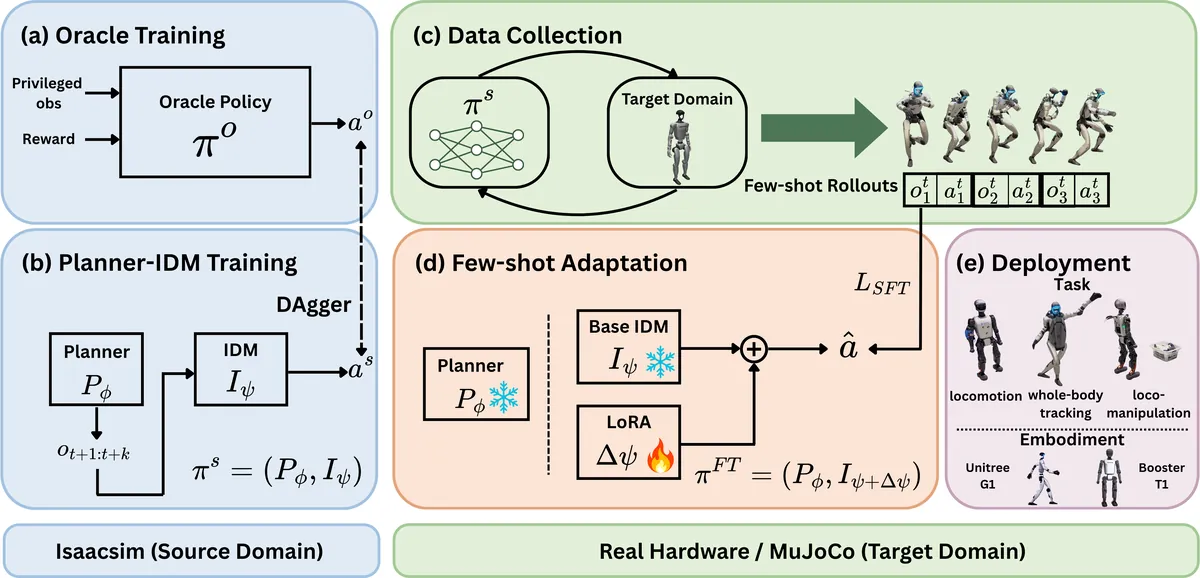
Adapts humanoid controllers to new robot dynamics using a few minutes of reward-free target rollouts.